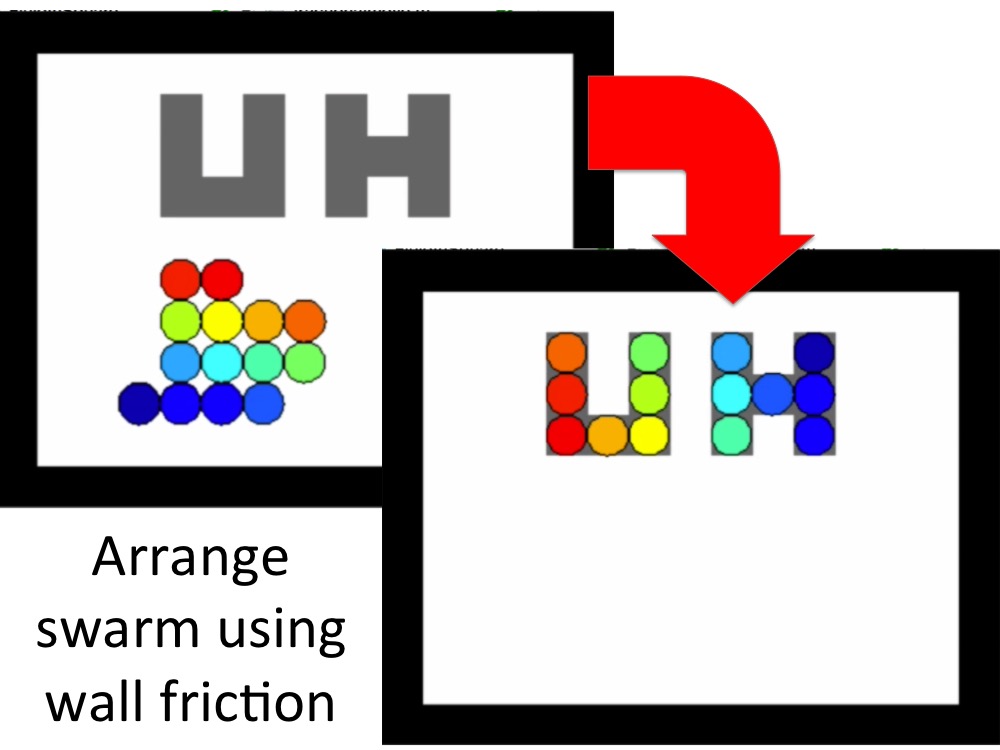
Arranging a robot swarm with global inputs and wall friction [discrete]
All robots get same input, but uses wall-friction to steer robots to a desired configuration.

You are now following this Submission
- You will see updates in your followed content feed
- You may receive emails, depending on your communication preferences
Cite As
Aaron T. Becker's Robot Swarm Lab (2026). Arranging a robot swarm with global inputs and wall friction [discrete] (https://www.mathworks.com/matlabcentral/fileexchange/54526-arranging-a-robot-swarm-with-global-inputs-and-wall-friction-discrete), MATLAB Central File Exchange. Retrieved .
General Information
- Version 1.0.0 (4.88 KB)
MATLAB Release Compatibility
- Compatible with any release
Platform Compatibility
- Windows
- macOS
- Linux
| Version | Published | Release Notes | Action |
|---|---|---|---|
| 1.0.0 | Added cover image |

