Defining Cartesian Reference Frames based on Point Positions
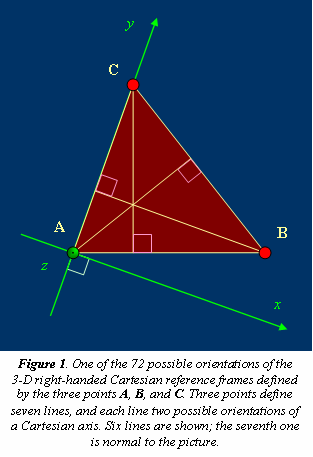
Defining 3-D Cartesian reference frames based on the positions of at least 3 non-collinear points
You are now following this Submission
- You will see updates in your followed content feed
- You may receive emails, depending on your communication preferences
Cite As
Paolo de Leva (2026). Defining Cartesian Reference Frames based on Point Positions (https://www.mathworks.com/matlabcentral/fileexchange/8787-defining-cartesian-reference-frames-based-on-point-positions), MATLAB Central File Exchange. Retrieved .
General Information
- Version 1.3.0 (49 KB)
MATLAB Release Compatibility
- Compatible with any release
Platform Compatibility
- Windows
- macOS
- Linux
| Version | Published | Release Notes | Action |
|---|---|---|---|
| 1.3.0 | Updated manual |
||
| 1.2.0 | New help text. More user-friendly version of function testFRAME. |
||
| 1.0.0 | The function name was changed from REFSYS to FRAME. A new sample function for computing anatomical reference frames of several human body segments was added. |

