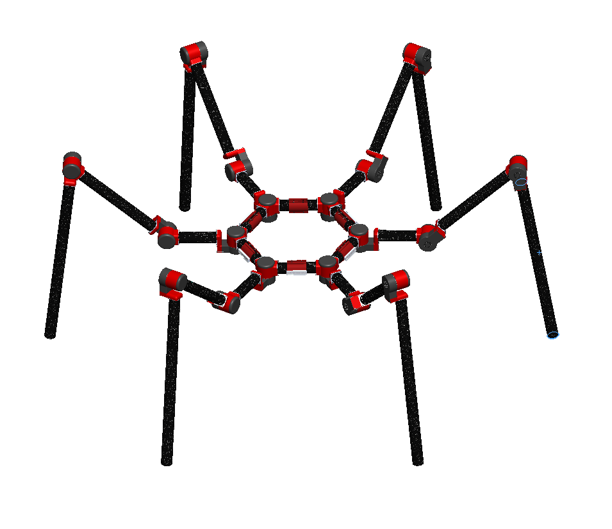
Hexapod Actuation
Allows a user to specify hexapod geometry, then calculates the joint torques and rotaitonal speeds required from actuators.

You are now following this Submission
- You will see updates in your followed content feed
- You may receive emails, depending on your communication preferences
Cite As
Matt Martone (2026). Hexapod Actuation (https://www.mathworks.com/matlabcentral/fileexchange/71712-hexapod-actuation), MATLAB Central File Exchange. Retrieved .
General Information
- Version 1.3.0 (158 KB)
MATLAB Release Compatibility
- Compatible with any release
Platform Compatibility
- Windows
- macOS
- Linux

