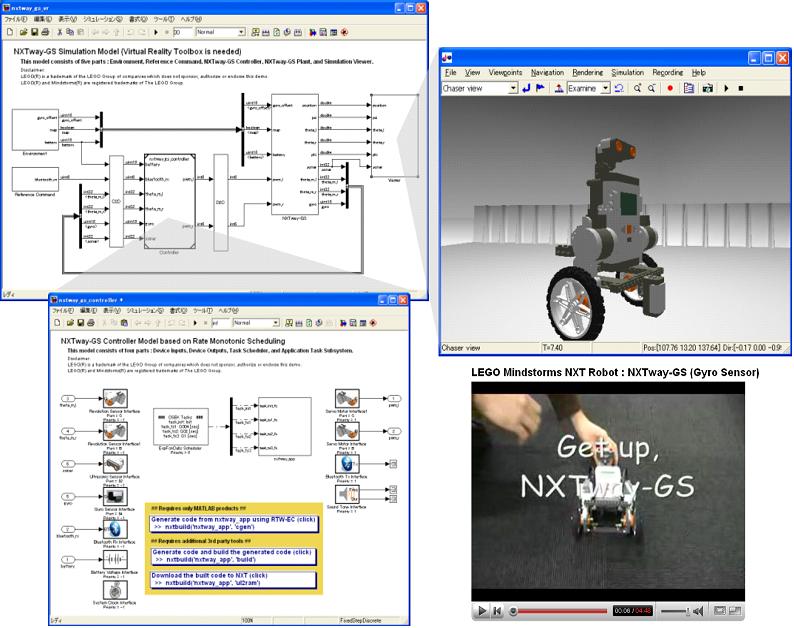
NXTway-GS (Self-Balancing Two-Wheeled Robot) Controller Design
NXTway-GS Model-Based Design based on Embedded Coder Robot NXT.

You are now following this Submission
- You will see updates in your followed content feed
- You may receive emails, depending on your communication preferences
Editor's Note: This file was selected as MATLAB Central Pick of the Week
Cite As
Yorihisa Yamamoto (2026). NXTway-GS (Self-Balancing Two-Wheeled Robot) Controller Design (https://www.mathworks.com/matlabcentral/fileexchange/19147-nxtway-gs-self-balancing-two-wheeled-robot-controller-design), MATLAB Central File Exchange. Retrieved .
Acknowledgements
Inspired by: Embedded Coder Robot NXT Demo, NXT SCARA (Two-Link Planar Robot Arm) Controller Design, NXT Ballbot (Self-Balancing Robot On A Ball) Controller Design
Inspired: Lego Mindstorms EV3 Gyroboy, Gyroboy - self-balancing two-wheel robot based on Lego EV3, Embedded Coder Robot NXT Demo, NXT SCARA (Two-Link Planar Robot Arm) Controller Design, NXT Ballbot (Self-Balancing Robot On A Ball) Controller Design, VU-LEGO Real Time Target
General Information
- Version 1.5.0 (11.3 MB)
MATLAB Release Compatibility
- Compatible with any release
Platform Compatibility
- Windows
- macOS
- Linux
| Version | Published | Release Notes | Action |
|---|---|---|---|
| 1.5.0 | 1.4 Modified text |
||
| 1.4.0 | updated building instructions
|
||
| 1.3.0 | Modified the generalized forces and state equations.
|
||
| 1.2.0 | 1.2+ Add an annotation to download the generated code into NXT standard firmware |
||
| 1.1.0 | 1.0 : First edition
|
||
| 1.0.0 |

