srs
R2026bSyntax
Description
returns the Shock Response Spectrum (SRS) for the base acceleration
signal S = srs(x,Fs)x with a sample rate Fs Hz that
stimulates an underdamped single-degree-of-freedom (SDOF) system.
[___] = srs(___,
specifies additional options using name-value arguments. You can specify the natural
frequencies to use in the SDOF system, the quality factor, the type of shock response,
among others.Name=Value)
srs(___) with no output arguments plots the SRS in
the current figure window or specified target parent container.
Examples
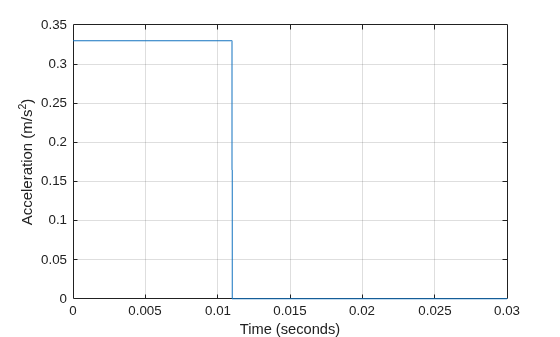
Generate and plot a rectangular-pulse acceleration signal with a width of 11 milliseconds, an amplitude of 0.33 , and a total duration of 30 milliseconds. The sample rate of the signal, Fs, is 100 kHz.
Fs = 1e5; tau = 11e-3; tEnd = 30e-3; t = (0:1/Fs:tEnd)'; x = 0.33.*(t<=tau); plot(t,x) xlabel("Time (seconds)") ylabel("Acceleration (m/s^2)") grid on
Calculate the SRS of the acceleration signal.
S = srs(x,Fs);
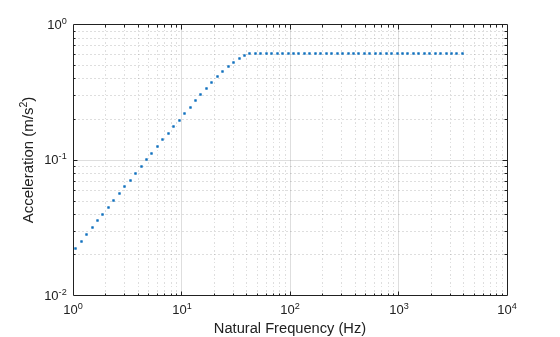
By default, the srs function associates S with a vector of natural frequencies, defined as an octave space from Fs/(3*2^15) to Fs/24 with six bands per octave. Use the default vector of natural frequencies to plot the SRS on a logarithmic scale.
f = freqoctspace(Fs/(3*2^15),Fs/24,6, ... OctaveRatioBase=2,ReferenceFrequency=1); figure loglog(f,S,".") xlabel("Natural Frequency (Hz)") ylabel("Acceleration (m/s^2)") grid on ylim([0.01 1])
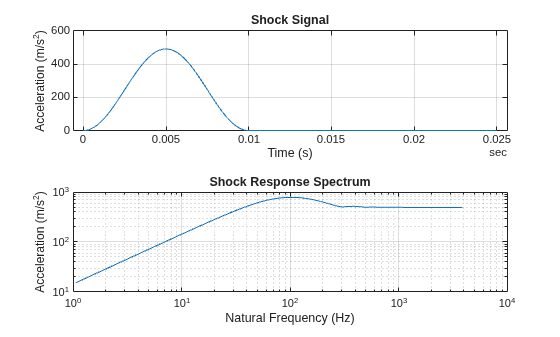
Generate a MATLAB® timetable containing a versed-sine acceleration signal with a width of 10 milliseconds and a total duration of 25 milliseconds. The sample rate of the shock signal is 100 kHz and the amplitude is 50 times the gravity acceleration on Earth.
Fs = 1e5; A = 50*9.81; tau = 0.010; T = 0.025; t = (0:1/Fs:T)'; vs = (A/2)*(1-cospi(2*t/tau)).*(t>=0 & t<=tau); vsTT = timetable(seconds(t),vs);
Compute the SRS of the acceleration signal timetable.
[S,Fn] = srs(vsTT);
Plot the shock signal and the corresponding SRS.
figure tiledlayout("vertical") nexttile plot(vsTT.Properties.RowTimes,vsTT{:,:}) title("Shock Signal") xlabel("Time (s)") ylabel("Acceleration (m/s^2)") grid on nexttile loglog(Fn,S) title("Shock Response Spectrum") xlabel("Natural Frequency (Hz)") ylabel("Acceleration (m/s^2)") grid on
Generate a vector containing a rectangular-pulse acceleration signal with a width of 7 milliseconds and a total duration of 10 milliseconds. The sample rate of the shock signal is 100 kHz and the amplitude is 10 times the gravity acceleration on Earth.
tWidth = 0.007; tPulse = 0.01; Fs = 1e5; t = (0:1/Fs:tPulse)'; x = 10*9.81*rectpuls(t,2*tWidth);
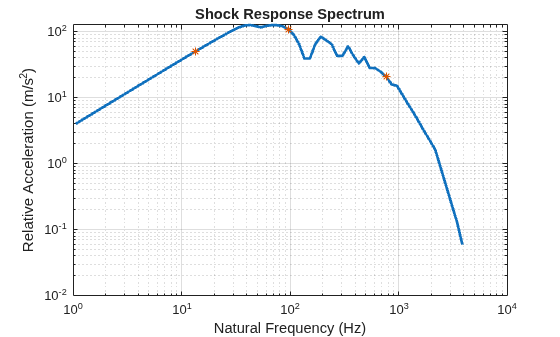
Compute and plot the residual relative-acceleration SRS of the shock signal. Assume SDOF systems with a quality factor of 5. Plot a point on the SRS values at three natural frequencies.
Q = 5; srsType = "relaccel"; respSeg = "residual"; [S,F,infoSDOF] = srs(x,Fs,QualityFactor=Q, ... ResponseType=srsType,ResponseSegment=respSeg,Parent=axes(figure)); hold on FnIdx = [23 40 58]; scatter(F(FnIdx),max(abs(infoSDOF.Responses(:,FnIdx))),"*") hold off
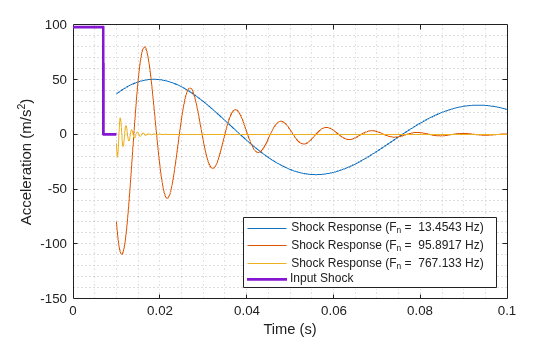
From the SDOF information array, infoSDOF, extract and plot the shock responses corresponding to each SRS. Plot the shock signal along with the shock responses.
The residual shock responses measure the effects after the shock signal excites the SDOF.
The maximum absolute values of the residual shock responses are approximately 50, 110, and 20 at the natural frequencies of 13.5 Hz, 95.9 Hz, and 767 Hz, respectively.
figure for i = FnIdx plot(infoSDOF.Time,infoSDOF.Responses(:,i), ... DisplayName=sprintf("Shock Response (F_n = %g Hz)",F(i))) hold on end plot(t,x,LineWidth=2,DisplayName="Input Shock") hold off xlim([0 0.1]) xlabel("Time (s)") ylabel("Acceleration (m/s^2)") legend(Location="southeast") grid minor
Generate a half-sine acceleration signal with a width of 7 seconds, a delay of 2 seconds, and a total duration of 11 seconds. The sample rate of the shock signal is 2 kHz and the amplitude is 1 .
tWidth = 7; tStart = 2; tPulse = 11; Fs = 2e3; t = (0:1/Fs:tPulse)'; x = sinpi((t-tStart)/tWidth).*(t>=tStart & t<=(tStart+tWidth));
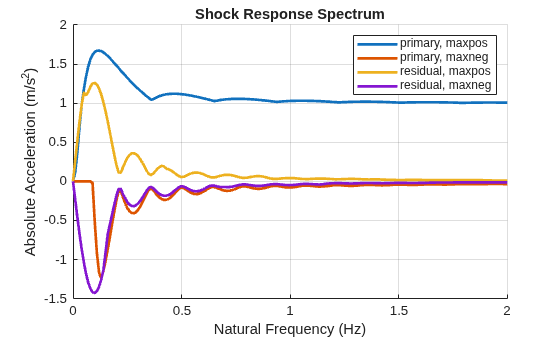
Plot the primary and residual SRS of the shock signal using the maximum positive and maximum negative shock responses. Assume a SDOF system with natural frequencies linearly distributed from 0 Hz to 2 Hz and a damping ratio of 0.04.
fn = linspace(0,2,201); Q = 1/(2*0.04); respSeg = ["primary" "residual"]; peakType = ["maxpos" "maxneg"]; ax = axes(figure); hold on for rs = respSeg for pt = peakType srs(x,Fs,NaturalFrequency=fn,QualityFactor=Q, ... ResponseSegment=rs,PeakType=pt,Parent=ax) end end hold off lgnd = reshape(respSeg + ", "+ peakType',[],1); legend(lgnd)
This example plots the SRS for several half-sine shock signals with a sample rate of 5 kHz. Define SDOF systems with a quality factor of 25 and natural frequencies ranging linearly from 0.01 Hz to 500 Hz.
Fs = 5e3; Q = 25; Fn = linspace(0.01,500,101);
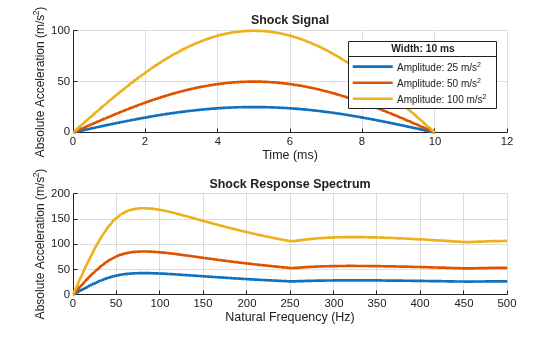
Plot the SRS of half-sine acceleration signals with a width of 10 milliseconds and amplitudes of 25, 50, and 100 . The absolute acceleration shown in each SRS is proportional to the amplitude of the corresponding half-sine acceleration signal.
A = [25 50 100]; W = 10*1e-3; tiledlayout(2,1) for a = A t = 0:1/Fs:W; x = a*sin(pi*t/W); ax = nexttile(1); hold on plot(1e3*t,x,LineWidth=2) nexttile(2) hold on srs(x,Fs,NaturalFrequency=Fn, ... QualityFactor=Q,RolloffMethod="none") end xlabel(ax,"Time (ms)") ylabel(ax,"Absolute Acceleration (m/s^2)") title(ax,"Shock Signal") axis(ax,[0 1.2e3*max(W) 0 max(A)]) grid(ax,"on") lgn = legend(ax,"Amplitude: " + A + " m/s^2"); title(lgn,"Width: " + 1e3*W + " ms")
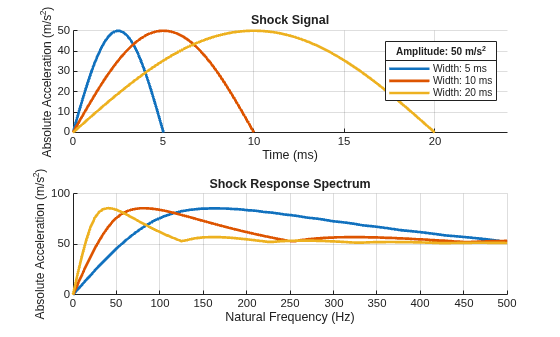
Plot the SRS of half-sine acceleration signals with an amplitude of width of 50 and widths of 5, 10, and 20 milliseconds. The transient shown in each SRS is inversely proportional to the width of the corresponding half-sine acceleration signal.
A = 50; W = [5 10 20]*1e-3; figure tiledlayout(2,1) for w = W t = 0:1/Fs:w; x = A*sin(pi*t/w); ax = nexttile(1); hold on plot(1e3*t,x,LineWidth=2) nexttile(2) hold on srs(x,Fs,NaturalFrequency=Fn, ... QualityFactor=Q,RolloffMethod="none") end xlabel(ax,"Time (ms)") ylabel(ax,"Absolute Acceleration (m/s^2)") title(ax,"Shock Signal") axis(ax,[0 1.2e3*max(W) 0 max(A)]) grid(ax,"on") lgn = legend(ax,"Width: " + 1e3*W + " ms"); title(lgn,"Amplitude: " + A + " m/s^2")
Generate a terminal-peak sawtooth acceleration signal with a width of 10 milliseconds. The sample rate of the shock signal is 20 kHz and the amplitude is 100 .
Fs = 20e3; A = 100; W = 0.01; tps = A*(0:1/Fs:W)/W;
When a SDOF system has a damping ratio of zero (infinite quality factor), the pseudo velocity spectrum at low frequency (close to 0 Hz) tends toward the area under the shock pulse. For a terminal-peak sawtooth shock waveform with amplitude and width , the area is .
area = sum(tps)/Fs
area = 0.5025
Compute and plot the pseudo-velocity SRS of the acceleration signal. Assume SDOF systems with an infinite quality factor and natural frequencies ranging in an octave space from 0.01 Hz to 1 kHz with 12 intervals per octave.
fn = freqoctspace(0.01,1e3,12); Q = Inf; fig = figure; ax = axes(fig); srspec = srs(tps,Fs,NaturalFrequency=fn,QualityFactor=Q, ... ResponseType="pseudovel",Parent=ax);
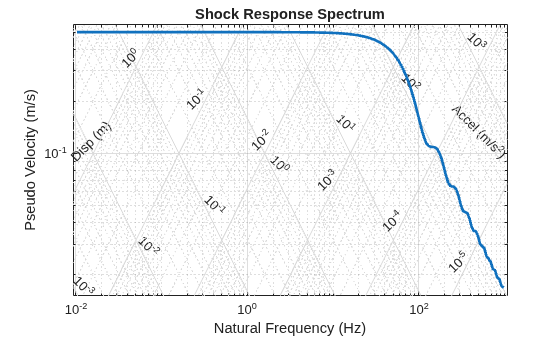
Display the pseudo velocity SRS value at the lowest natural frequency and compare it with the area under the shock pulse.
fprintf("Area under shock = %.4f\n" + ... "Pseudovelocity at low frequency = %.4f\n",area,srspec(1))
Area under shock = 0.5025 Pseudovelocity at low frequency = 0.5025
Input Arguments
Base acceleration signal in m/s2, specified as a real-valued vector, matrix, or timetable.
This argument represents the base acceleration in m/s2 that stimulates an underdamped SDOF oscillator.
The signal must have at least nine elements if
xis a vector, or nine rows ifxis a matrix or a timetable.All the elements in
xmust be finite.If you specify
xas a matrix, then thesrsfunction interprets its columns as individual channels.If you specify
xas a timetable:xmust be uniformly sampled.xcan have one variable with multiple channels, or multiple variables with one channel each.
Only timetables that use a
durationordatetimevector forRowTimesare supported.
Example: x = randn(5000,12) specifies a random with 5000
samples and 12 channels. To specify the sample rate or sample time,use
Fs.
Example: x = timetable(randn(5000,12),SampleRate=1e3)
specifies a 12-channel random variable sampled at 1 kHz for 5 seconds.
Data Types: single | double
Sample rate, specified as a numeric scalar.
The function uses the value specified in this argument to calculate the times associated with the vector or matrix
x.This argument does not apply if
xis a timetable.
Data Types: single | double
Name-Value Arguments
Specify optional pairs of arguments as
Name1=Value1,...,NameN=ValueN, where Name is
the argument name and Value is the corresponding value.
Name-value arguments must appear after other arguments, but the order of the
pairs does not matter.
Example: [S,Fn] =
srs(rand(1000,1),2e3,QualityFactor=7,ResponseType="relvel") computes the
relative-velocity SRS of a 1000-sample base acceleration signal sampled at a rate of 2 kHz,
where the underlying SDOF uses a quality factor of 7.
Natural frequencies in Hz, specified as a vector of nonnegative values less than or equal to the Nyquist rate.
By default, the srs function uses the sample rate
Fs to generate the natural frequencies as a logarithmically
spaced vector from Fs/(3*2^15) to Fs/24 with a
space of one sixth of octave.
The function uses the minimum natural frequency of
Fs/(3*2^15)to ensure sufficient frequency resolution to accurately estimate low-frequency SDOF responses.The function uses the maximum natural frequency of
Fs/24to aim a peak estimation error under 1% at high frequencies.The function uses the 1/6 octave spacing between natural frequencies to follow the MIL-STD-810H standard [1], and offers a practical balance between frequency resolution and statistical independence across shock response spectrum estimates.
To generate frequency vector with octave spacing, you can use the
freqoctspacefunction. Given the sample rateFs, this code generates the default 72-element vector of natural frequencies,NFreqs, if you do not specifyNaturalFrequency.NFreqs = freqoctspace(Fs/(3*2^15),Fs/24,6,OctaveRatioBase=2,ReferenceFrequency=1);
You can alternatively use the
logspacefunction to generate a logarithmically spaced vector of natural frequencies.
Data Types: single | double
Quality factor, specified as positive scalar greater than 0.5.
The quality factor Q and the damping ratio ζ of the underlying SDOF system are related by Q = (2ζ)–1.
The SDOF system must be underdamped (ζ < 1), thus Q must be greater than 0.5.
The default value for this argument (Q = 10) considers a 5% damping ratio (ζ = 0.05).
Data Types: single | double
Type of shock response, specified as one of these values:
"absaccel"— Absolute acceleration"relaccel"— Relative acceleration"pseudoaccel"— Pseudo acceleration, defined as ξ·ω2n, where:ξ is the relative displacement.
ωn is the natural angular frequency.
"relvel"— Relative velocity"pseudovel"— Pseudo velocity, defined as ξ·ωn."reldisp"— Relative displacement
The function computes the SRS based on the type of shock response specified in this argument.
Data Types: char | string
Segment of the shock response from which to compute the SRS, specified as one of these values:
"full"— Use the time range associated with the inputxand the post-input response."primary"— Use the time range associated with the input only."residual"— Use the time range associated with the post-input response only.
The function computes the SRS using the peak response at the times corresponding to the type of time range specified in this argument.
If you specify this argument as "full" or
"residual", then the function pads the input signal with zeros
for the time range associated with the post-input response.
The number of padded zeros equals the duration of one period at the lowest natural frequency. For a vector of natural frequencies
NFreqsspecified inNaturalFrequencyand a sample rateFs, the number of padded zeros equalsceil(Fs/min(NFreqs)).If
NaturalFrequencycontains a 0 Hz frequency, then the function does not perform zero padding.
Data Types: char | string
Length of the shock signal, specified as a positive integer (number of samples) or
as a duration scalar (time in seconds).
The shock signal defines the time window over which the primary excitation is assumed to occur.
The value specified in this argument cannot exceed the total length or duration of the input signal
x.You can specify this argument only if you specify
ResponseSegmentas"primary"or"residual".If you specify
ShockLengthas adurationscalar, the specified value must be at leastorseconds(1/Fs)Ts, so that the length of the shock signal spans at least one sample.
Data Types: single | double
Method to extract the peak response, specified as "maximax",
"maxneg", ."maxpos", or
"rms".
Assume a shock response s, which is the response of a SDOF to
the input x, then the function extracts the peak response
p depending on the value specified in this argument:
"maximax"—srsfinds the absolute maximum peak, p = max(abs(s))."maxneg"—srsfinds the maximum value in the negative direction, p = min(s)."maxpos"—srsfinds the maximum value in the positive direction, p = max(s)."rms"—srscomputes the root-mean-square of the shock response, p =rms(s).
Data Types: char | string
Method to preprocess the base acceleration signal x,
specified as one of these values:
"prefilter"—srsfiltersxusing a zero-phase third-order filter with a high-frequency gain. The function uses this method to compensate for the attenuation that the ramp-invariant transformation introduces. For more information, see Algorithms."resample"—srsresamplesxusing an FIR antialiasing lowpass filter.The function uses this method to enforce the points-per-cycle requirement that you specify in
PointsPerCycle."interp"—srslinearly interpolatesxusing shape-preserving piecewise cubic polynomials.The function uses this method to enforce the points-per-cycle requirement that you specify in
PointsPerCycle."none"—srsdoes not preprocessx.
The function then uses the preprocessed base acceleration signal to compute the shock response.
Data Types: char | string
Minimum number of points per cycle to compute the shock response, specified as a positive integer.
Assume a vector of natural frequencies specified as
, a sample rate
NaturalFrequency=NFreqsFs, and the minimum number of points per cycle specified as
.PointsPerCycle=Nppc
If max(
NFreqs)/Fs<Nppc, then the function interpolates or resamples the base acceleration signalxto satisfy the required number of points per cycle.Lower values of
Nppcdecrease the computation accuracy while higher values ofNppcincrease the computation time.The maximum peak error is emax = 1 – cos(π/
Nppc), so the default valueNppc = 12corresponds to emax = 0.034 (3.4%).
This argument applies only if you specify RolloffMethod as
"resample" or "interp".
Data Types: single | double
Target parent container, specified as an Axes object, a UIAxes object, or a Panel object.
If you specify Parent, the srs
function plots the SRS on the specified target parent container, whether you call the
function with or without output arguments.
For more information about target containers and the parent-child relationship in
MATLAB graphics, see Graphics Object Hierarchy. For more
information about using Parent in UIAxes and
Panel objects to design apps, see Plot Spectral Representations of Signal in App Designer.
Output Arguments
Shock response spectrum (SRS), returned as a column vector or a matrix with as many
columns as x.
Natural frequencies, returned as a column vector with as many rows as
S.
If you specify NaturalFrequency, then the function returns the
specified vector in Fn.
SRS information, returned as a struct array that comprises the following fields:
Time— Times associated with the shock response, returned as a column vector.The function does not return
Timeifxis a timetable. Instead, the function returnsResponsesas a timetable with the corresponding time information.Responses— Shock responses in the time domain, returned as one of these:Matrix with as many columns as natural frequencies — Each column corresponds to a natural frequency.
3-D array with as many pages as natural frequencies — Each column corresponds to a channel or column of
x, while each page corresponds to a natural frequency.Timetable — Each variable is a 3-D array where each row corresponds to a time instance, each column corresponds to a channel or column of
x, while each page corresponds to a natural frequency.
Systems— SDOF system information, returned as astructarray that comprises these fields:Numerator— Numerator coefficients of the SDOF system, returned as a matrix with as many rows as natural frequencies. The ith column corresponds to the z–(i-1) term.Denominator— Denominator coefficients of the SDOF system, returned as a matrix with as many rows as natural frequencies. The ith column corresponds to the z–(i-1) term.IsStable— SDOF stability status at each natural frequency, returned as a column vector.To determine stability,
srsuses theisstablefunction and theCoefficientsfield. For the natural frequencies at which the SDOF system is unstable, the function returns0in the corresponding rows ofIsStable. At these frequencies, the computed SRS might be inaccurate.
More About
The shock response spectrum (SRS, [2][3]) is a graphical representation that illustrates the maximum responses (typically output acceleration) of a set of linear SDOF systems that undergo mechanical excitation (typically input acceleration). Plotting the SRS constitutes a technique used to characterize the shock effect on a standardized dynamic system and estimate its severity or destructive potential. Analyze the SRS to determine if a system can survive a shock environment, design the system to withstand shock environments, and specify shock tests [4].
A linear SDOF system comprises a mass m, a spring with stiffness k, and a damper with viscous damping coefficient c. A massless base sustains the mass and the damper and constitutes the reference framework of the system.
is the input acceleration at the base (shock signal) and is the SDOF input.
is the measured absolute acceleration at the mass (shock response) and is the SDOF output.
The response of the SDOF system is the solution of the equation of motion,
,
where is the relative displacement of the mass, is the natural angular frequency of the system, and is the quality factor of the system.
If the initial relative displacement and velocity of the system are both zero, then the solution to the equation of motion is given by the convolution of – with the unit impulse response of the SDOF system, which is
,
where is the damping ratio, and is the damped natural angular frequency.
From the equation of motion, the shock response, , is
.
Assume a 10-millisecond versed-sine base acceleration (in m/s2),
This figure illustrates the shock response, , for the shock signal , given a natural angular frequency of 360π rad/s and a quality factor of 10.
The peak value is the most important characteristic in a shock response signal because
it determines the worst shock scenario. Depending on how you specify
PeakType, you can select one of these types of peaks in the shock response:
Maximax, which is the maximum absolute value or max(||).
Maximum negative, which is the most negative value or min().
Maximum positive, which is the most positive value or max().
RMS, which is the root mean square or
rms().
The excitation duration determines three types of shock response
segments, regions of interest in the time domain. Depending on how you
specify ResponseSegment, you can select one of these shock response segments:
Primary response, which occurs while the shock signal is exciting the SDOF system. This segment captures the immediate dynamic loading of the system and is useful to analyze shocks with high frequency and short duration.
Residual response, which occurs after the shock signal no longer excites the SDOF system. This segment captures the effects of free vibration of the system and is useful to analyze shocks with low frequency in lightly damped systems.
Full response, which comprises both the primary and residual responses. This response provides a comprehensive time-domain analysis of the system dynamics and helps system designers ensure appropriate design margins in conservative or worst-case scenarios.
While the shock response is typically the absolute acceleration, , you can compute other types of shock response. Depending on how you
specify ResponseType, you can compute one of these types of shock response:
Absolute acceleration,
Relative acceleration,
Pseudo acceleration,
Relative velocity,
Pseudo velocity,
Relative displacement,
To generate the SRS from a base acceleration signal , the srs function:
Calculates the shock response of each SDOF oscillator at its corresponding natural frequency .
To select a preprocessing method for the base acceleration signal before calculating the shock response, specify
RolloffMethod.To customize the quality factor of the SDOF oscillator, specify
QualityFactor.
Selects the peak value from each shock response, which depends on the peak type and the response segment.
To select a peak type in the shock response, specify
PeakType.To select a shock response segment in the shock response, specify
ResponseSegment.
Repeats Step 1 and Step 2 for each natural frequency specified in
NaturalFrequency.
This figure illustrates the synthesis of an SRS from the peak shock-response values across natural frequencies.
Algorithms
By default (if you set RolloffMethod to
"prefilter"), the srs function uses the
prefilter-Smallwood method [5], which uses ramp
invariance to convert the transfer function to an equivalent digital filter with unit DC
response.
In this case,
srsusesfiltfiltto zero-phase filterxfor ramp invariance, and then uses Smallwood's method [6] to compute the SRS ofx.Aliasing is the main reason that the digital filter obtained from the impulse-invariant method does not have a unit DC response. Thus, ramp invariance connects impulse-response samples with straight lines to decrease aliasing.
If you set RolloffMethod to "none",
then srs does not perform zero-phase filtering and uses
Smallwood's method to compute the SRS of x.
References
[1] Environmental Engineering Considerations and Laboratory Tests — Test Method Standard (2019). MIL-STD-810H. Melville, NY: US Department of Defense.
[2] Lalanne, C. (2009) Mechanical Vibration and Shock Analysis. Vol. 2: Mechanical Shock / Christian Lalanne. Second edition, London: ISTE.
[3] Piersol, A. G., Paez, T. L., and Harris, C M. (2010) Harris’ Shock and Vibration Handbook. 6th ed. New York: McGraw-Hill.
[4] Kelly, R. D., and Richman, G. (1969) Principles and Techniques of Shock Data Analysis. Washington: Naval Research Laboratory.
[5] Ahlin, K. (1999) "Shock Response Spectrum Calculation - An Improvement of the Smallwood Algorithm." 70th Shock and Vibration Symposium. SAVIAC.
[6] Smallwood, D. O. “Improved Recursive Formula for Calculating Shock Response Spectra.” (1980) Shock and Vibration Bulletin, Vol. 51, Number 2, pp. 211–17.
Extended Capabilities
C/C++ Code Generation
Generate C and C++ code using MATLAB® Coder™.
GPU Code Generation
Generate CUDA® code for NVIDIA® GPUs using GPU Coder™.
The srs function supports
thread-based environments with these usage notes and limitations:
The syntax with no output arguments is not supported.
For more information, see Run MATLAB Functions in Thread-Based Environment.
The
srs function fully supports GPU arrays.
To run the function on a GPU, specify the input data as a gpuArray (Parallel Computing Toolbox). For more
information, see Run MATLAB Functions on a GPU (Parallel Computing Toolbox).
Version History
Introduced in R2026b
See Also
MATLAB Command
You clicked a link that corresponds to this MATLAB command:
Run the command by entering it in the MATLAB Command Window. Web browsers do not support MATLAB commands.
Select a Web Site
Choose a web site to get translated content where available and see local events and offers. Based on your location, we recommend that you select: .
You can also select a web site from the following list
How to Get Best Site Performance
Select the China site (in Chinese or English) for best site performance. Other MathWorks country sites are not optimized for visits from your location.
Americas
- América Latina (Español)
- Canada (English)
- United States (English)
Europe
- Belgium (English)
- Denmark (English)
- Deutschland (Deutsch)
- España (Español)
- Finland (English)
- France (Français)
- Ireland (English)
- Italia (Italiano)
- Luxembourg (English)
- Netherlands (English)
- Norway (English)
- Österreich (Deutsch)
- Portugal (English)
- Sweden (English)
- Switzerland
- United Kingdom (English)