Gain Scheduling
R2026bA gain-scheduled controller is a controller whose gains are
automatically adjusted as a function of time, operating condition,
or plant parameters. Gain scheduling is a common strategy for controlling
systems whose dynamics change with time or operating condition. Such
systems include linear parameter-varying (LPV) systems and large classes
of nonlinear systems. To tune gain-scheduled controllers in Simulink®, you
represent the variable gain as a function of the scheduling variables
using the tunableSurface command. For an overview
of the workflow for tuning gain-scheduled controllers, see Gain Scheduling Basics.
Functions
Blocks
 | Varying Lowpass Filter | Butterworth filter with varying coefficients |
 | Varying Notch Filter | Notch filter with varying coefficients |
 | PID Controller | Continuous-time or discrete-time PID controller |
 | PID Controller (2DOF) | Continuous-time or discrete-time two-degree-of-freedom PID controller |
 | Varying Transfer Function | Transfer function with varying coefficients |
 | Varying State Space | State-space model with varying matrix values |
 | Varying Observer Form | Observer-form state-space model with varying matrix values |
 | Discrete Varying Lowpass | Discrete Butterworth filter with varying coefficients |
 | Discrete Varying Notch | Discrete-time notch filter with varying coefficients |
 | Discrete PID Controller | Discrete-time or continuous-time PID controller |
 | Discrete PID Controller (2DOF) | Discrete-time or continuous-time two-degree-of-freedom PID controller |
 | Discrete Varying Transfer Function | Discrete-time transfer function with varying coefficients |
 | Discrete Varying State Space | Discrete-time state-space model with varying matrix values |
 | Discrete Varying Observer Form | Discrete-time observer-form state-space model with varying matrix values |
 | Gain-Scheduled PID Autotuner | Automatically tune PID gains at multiple operating points (Since R2024a) |
 | Closed-Loop PID Autotuner | Automatically tune PID gains based on plant frequency responses estimated from closed-loop experiment in real time |
 | Change Operating Points | tSwitch between operating points during simulation (Since R2023b) |
 | PID Gain Scheduler | Lookup table based gain scheduling with PID array (Since R2023b) |
 | PID Gains Store and Update | Store and update tuned PID gains tuned using Closed-Loop PID Autotuner (Since R2023b) |
Topics
Gain-Scheduled Control Systems
- Gain Scheduling Basics
Gain scheduling is an approach to control of non-linear systems using a family of linear controllers, each providing satisfactory control for a different operating point of the system. - Model Gain-Scheduled Control Systems in Simulink
In Simulink, model gain schedules using lookup tables, interpolation blocks, or MATLAB Function blocks.
Tune Gain Schedules
- Tune Gain Schedules in Simulink
Understand the general tuning workflow for usingsystuneto tune gain-scheduled controllers. - Plant Models for Gain-Scheduled Controller Tuning
To tune a gain-scheduled control system, you need a collection of linear models describing the plant dynamics at the selected design points. - Multiple Design Points in slTuner Interface
For tuning a gain-scheduled control system, associate a family of linear plant models with theslTunerinterface to your Simulink model. - Parameterize Gain Schedules
A gain surface parameterizes a variable gain in terms of the scheduling variables. Use gain surfaces to model variable gains in a gain-scheduled control system. - Change Requirements with Operating Condition
When tuning gain-scheduled controllers, you can specify tuning objectives that depend on the scheduling variables. - Validate Gain-Scheduled Control Systems
Tuning gain-scheduled controllers guarantees suitable performance only near each design point. It is important to validate the tuning results over the full range of operating conditions.
Gain-Scheduled Autotuning
- Gain-Scheduled PID Autotuning a VTOL UAV During Forward and Backward Transition
Tune gain-scheduled PID controller for VTOL UAV transitioning between operating modes. (Since R2024a) - Gain-Scheduled PID Autotuning Torque Control for a Nonlinear PMSM
Tune gain-scheduled PID controllers for d-axis and q-axis current loops of a nonlinear PMSM model. (Since R2024a)
HL-20 Autopilot Case Study
- Trimming and Linearization of the HL-20 Airframe
Linearize an airframe model at an array of design points to use for gain-scheduled control design. - Angular Rate Control in the HL-20 Autopilot
Tune gain-scheduled PI controllers for the inner loop of the HL-20 airframe model. - Attitude Control in the HL-20 Autopilot - SISO Design
Tune a gain-scheduled SISO architecture for controlling roll, pitch, and yaw of the airframe. - Attitude Control in the HL-20 Autopilot - MIMO Design
Tune a gain-scheduled MIMO architecture for controlling roll, pitch, and yaw of the airframe. - MATLAB Workflow for Tuning the HL-20 Autopilot
Design a gain-scheduled control system for the HL-20 airframe in MATLAB®.
Related Information
Featured Examples
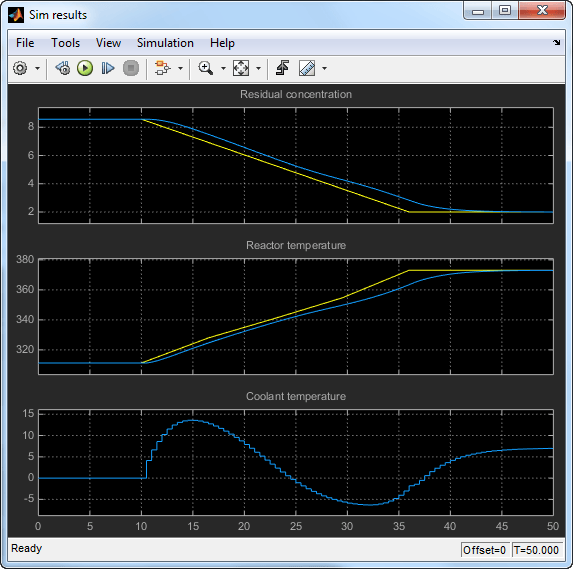
Gain-Scheduled Control of a Chemical Reactor
Tune a gain-scheduled controller for a chemical reactor transitioning from low to high conversion rate.
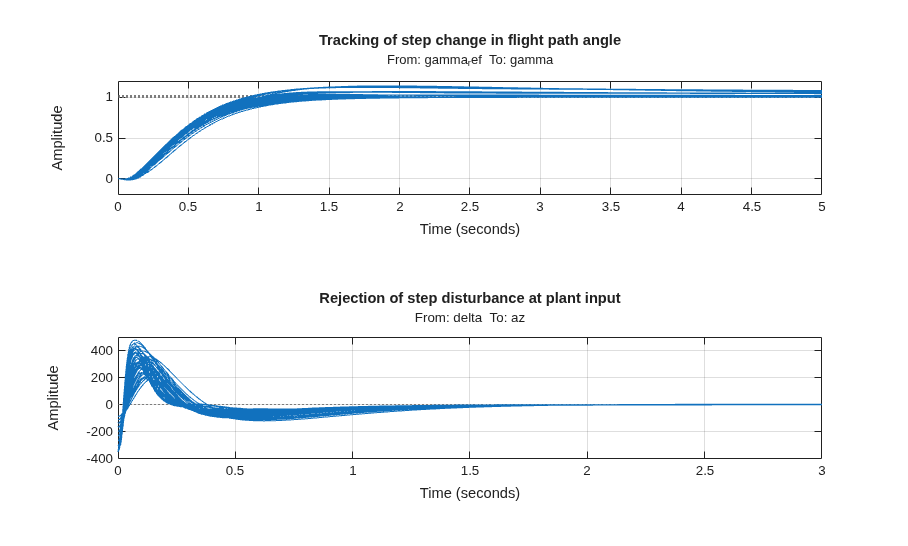
Tuning of Gain-Scheduled Three-Loop Autopilot
Uses systune to generate smooth gain-schedules for a
two-dimensional grid of operating conditions for a control system modeled in Simulink.
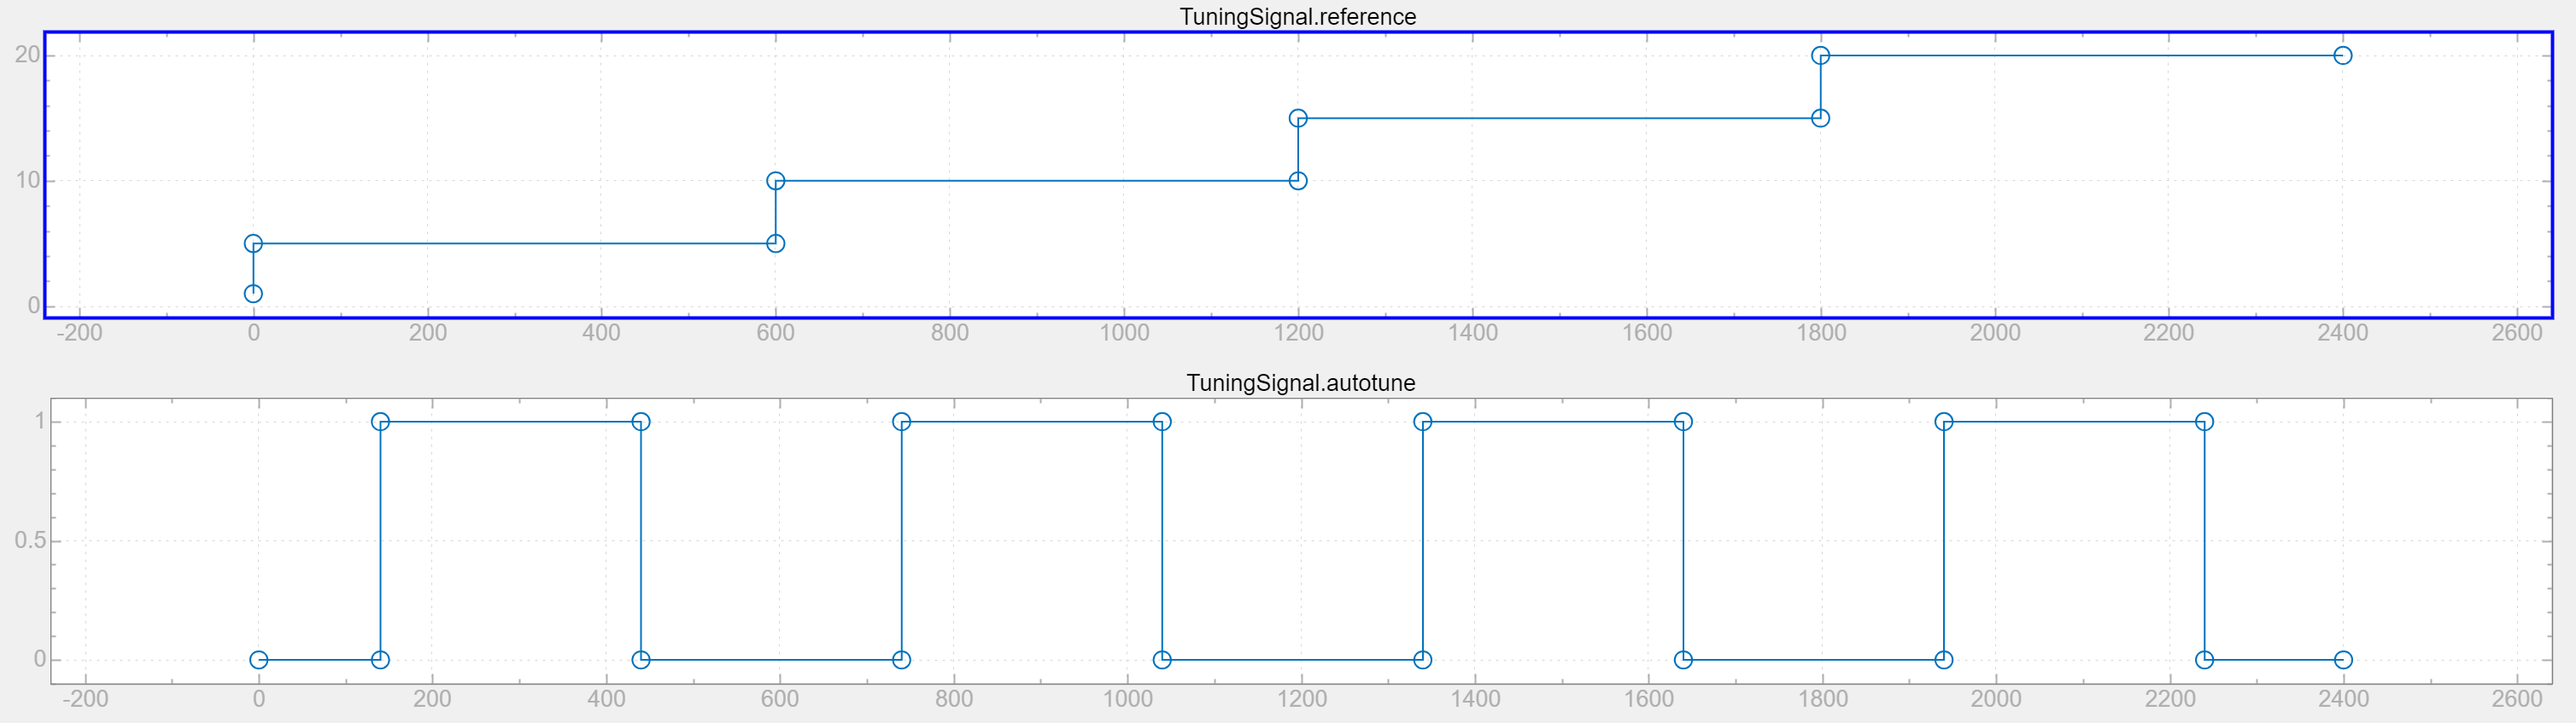
Tune Gain-Scheduled Controller Using Closed-Loop PID Autotuner Block
Use Closed-Loop PID Autotuner block to tune gain-scheduled PID controller for a water-tank model in one simulation.
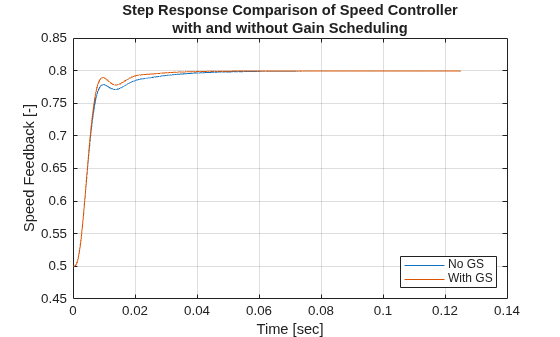
Tune Gain-Scheduled Controller for PMSM Model Using Closed-Loop PID Autotuner Block
Use Closed-Loop PID Autotuner block to tune gain-scheduled PI controller for a PMSM model in one simulation.
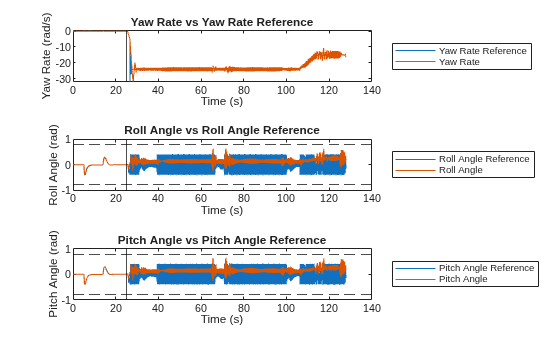
UAV Inflight Failure Recovery with Reference Trajectory Tracking
Design a controller to recover a UAV experiencing rotor fault.

