Calibrate Cameras
R2026bCamera calibration is the process of estimating camera parameters by using images that contain a calibration pattern. The parameters include camera intrinsic parameters, distortion coefficients, and camera extrinsic parameters. Use these camera parameters to remove lens distortion effects from an image, measure planar objects, reconstruct 3-D scenes from multiple cameras, and perform other computer vision applications.
Fisheye camera calibration extends this process by estimating parameters and distortion coefficients specific to fisheye lenses, which is essential for correcting extreme distortion and accurately mapping image points to real-world coordinates in applications such as SLAM, odometry, surveillance, VR, and image stitching. You can use the Camera Calibrator app and functions for single-camera intrinsic parameters, extrinsic parameters, and distortion, the Stereo Camera Calibrator app and functions for stereo parameters and relative orientations, and the dedicated fisheye calibration functions for distortion removal and accurate wide-angle 3-D reconstruction. For information on calibrating multiple sensors in a system, see Calibrate Multi-Sensor Systems.
Apps
| Camera Calibrator | Estimate geometric parameters of a single camera |
| Stereo Camera Calibrator | Estimate geometric parameters of a stereo camera |
| Multi-Camera Calibrator | Calibrate multiple cameras (Since R2026b) |
Functions
Topics
Get Started
- What Is Camera Calibration?
Estimate the parameters of a lens and image sensor of an image or video camera. - Using the Single Camera Calibrator App
Prepare camera calibration images and estimate camera intrinsic parameters. - Using the Stereo Camera Calibrator App
Calibrate a stereo camera, which you can then use to recover depth from images. - Using the Multi-Camera Calibrator App
Calibrate a multi-camera system to estimate the relative poses of cameras. - Fisheye Calibration Basics
Fisheye camera model and calibration in MATLAB. - Coordinate Systems
Specify pixel indices, spatial coordinates, and 3-D coordinate systems. - Point Feature Types
Choose functions that return and accept points objects for several types of features.
Data Collection Guidelines
- Calibration Patterns
Camera calibration using a checkerboard, circle grid, or custom detector pattern. - Data Collection Guidelines for Single-Camera Calibration
Set up your camera and capture camera calibration images to use with the calibrator app.
Featured Examples
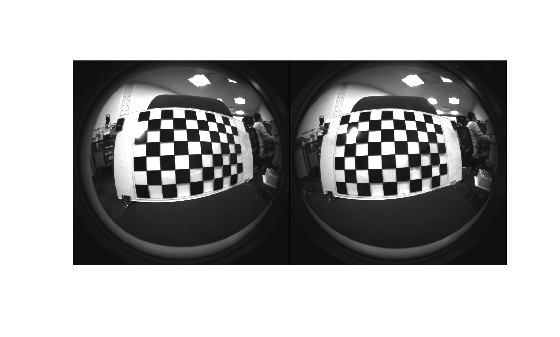
Stereo Fisheye Camera Calibration
Calibrate a stereo fisheye camera by determining each camera's intrinsic parameters and estimate the baseline between them.
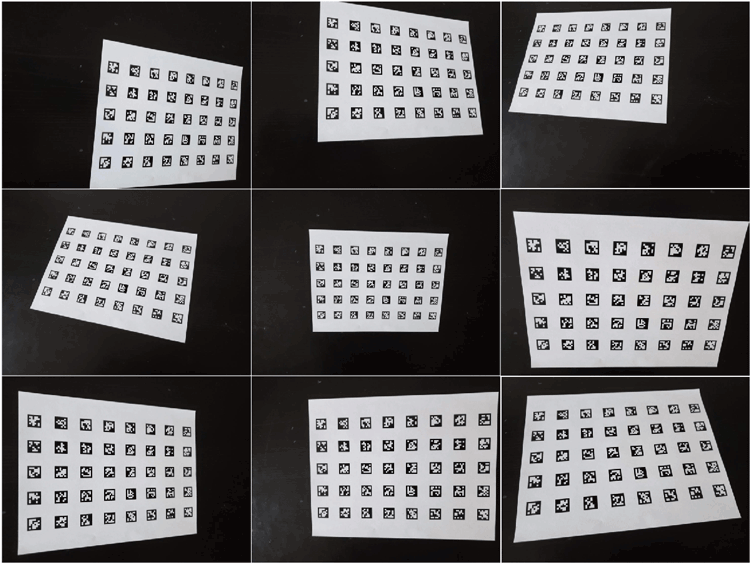
Camera Calibration Using Custom Planar Calibration Patterns
Detect and localize AprilTags in a calibration pattern.
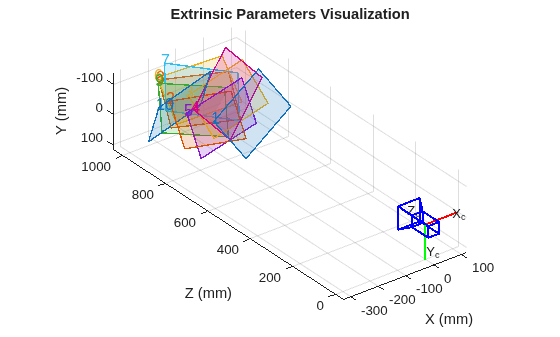
Evaluating the Accuracy of Single Camera Calibration
Evaluate the accuracy of estimated camera parameters.
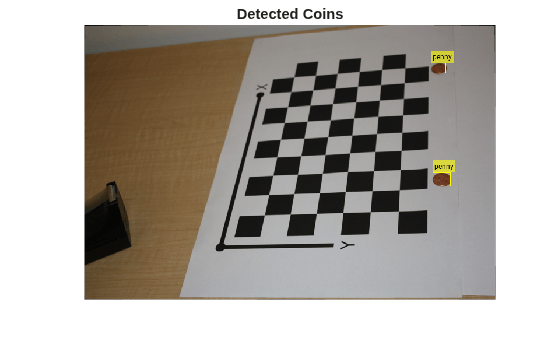
Measuring Planar Objects with a Calibrated Camera
Measure the diameter of coins in world units using a single calibrated camera.
Configure Monocular Fisheye Camera
Convert a fisheye camera model to a pinhole model.

